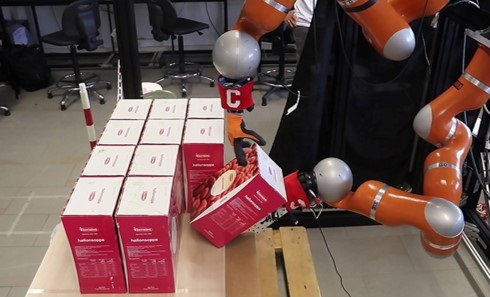
Dual-arm picking & packing
End-to-end software for production dual-arm case packers running at up to 30,000 eggs/hour: perception, collision-aware manipulation, time-optimal trajectories, control, simulation, CI and operator tooling.
Robotics & Robot Learning Engineer
Senior Software Robotics Engineer at Witty Machines in Zurich. Ph.D. in Robotics, co-founder of XStar Motion. I take robotic systems from research prototypes to production machines.
I am a senior robotics and robot learning engineer specializing in manipulation, reinforcement learning, imitation learning, motion planning and control. I work end to end across perception, planning, control, ML, simulation and software infrastructure, and I have taken systems from research prototypes to deployed production machines.
Today I am based in Zurich at Witty Machines, where I own the robotics software stack of production dual-arm picking and packing systems. Before that I led manipulation at Floating Robotics and held a postdoctoral and assistant professor position at the University of Pisa, where I earned my Ph.D. in Robotics (with honors) and spent time as a visiting researcher at Stanford.
I am also co-founder and scientific advisor of XStar Motion, a start-up developing industrial motion-optimization algorithms.
My research focused on planning and decision-making algorithms for collaborative robots in unstructured environments, within international, industry-oriented projects such as ILIAD, DARKO and SOPHIA. My thesis, “Shaping the Intelligence of Collaborative Robots in Interaction-Rich Shared Environments”, was a finalist for the Georges Giralt PhD Award.
Planning, implementing and testing manipulation algorithms on dual-arm platforms.
Grasp planners for robots with rigid and compliant grippers.
Optimal, safety-aware trajectories for robots working next to humans.
17 publications · 500+ citations · h-index 11 · Full list on Google Scholar · dblp
Italian (native) · English (advanced) · German (basic)
End-to-end software for production dual-arm case packers running at up to 30,000 eggs/hour: perception, collision-aware manipulation, time-optimal trajectories, control, simulation, CI and operator tooling.
Motion planning and control for a harvesting robot, contributing to a 40% increase in harvest efficiency and 24 kg/h harvesting rate, plus visuomotor policy evaluation (ACT, VIOLA).
Online time-optimal trajectory generation under velocity, acceleration and jerk limits for robots and CNC machines, achieving a 10% reduction in machine wear.
Visit XStar Motion →


Machines I have worked on, in action. Click a video to play it here; the player loads only when you do.
My research on optimal trajectory planning led to XStar Motion, a start-up that aims to transform the way the motion of machines is planned.
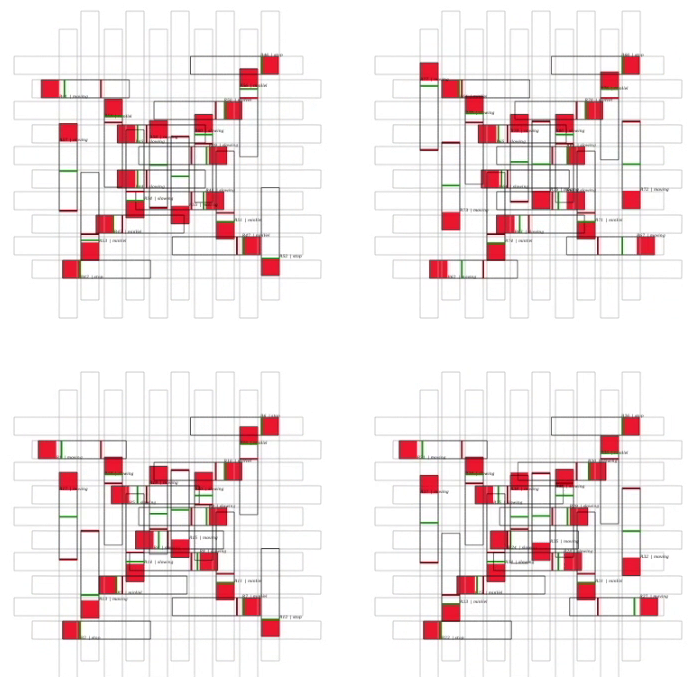
We developed X*Solve, an algorithm that computes the optimal trajectory along a working-cycle path while respecting the machine's velocity, acceleration and jerk limits. It runs online, delivering optimized references at the controller frequency, and integrates with both robots and CNC machines.
XStar Motion combines 20 years of automation expertise from EUROSOFT with cutting-edge research in motion planning and control from the University of Pisa. Today's AI theory, algorithms and computing power make it possible to plan the motion of every machine to exploit its full potential, and to update it autonomously for every task.